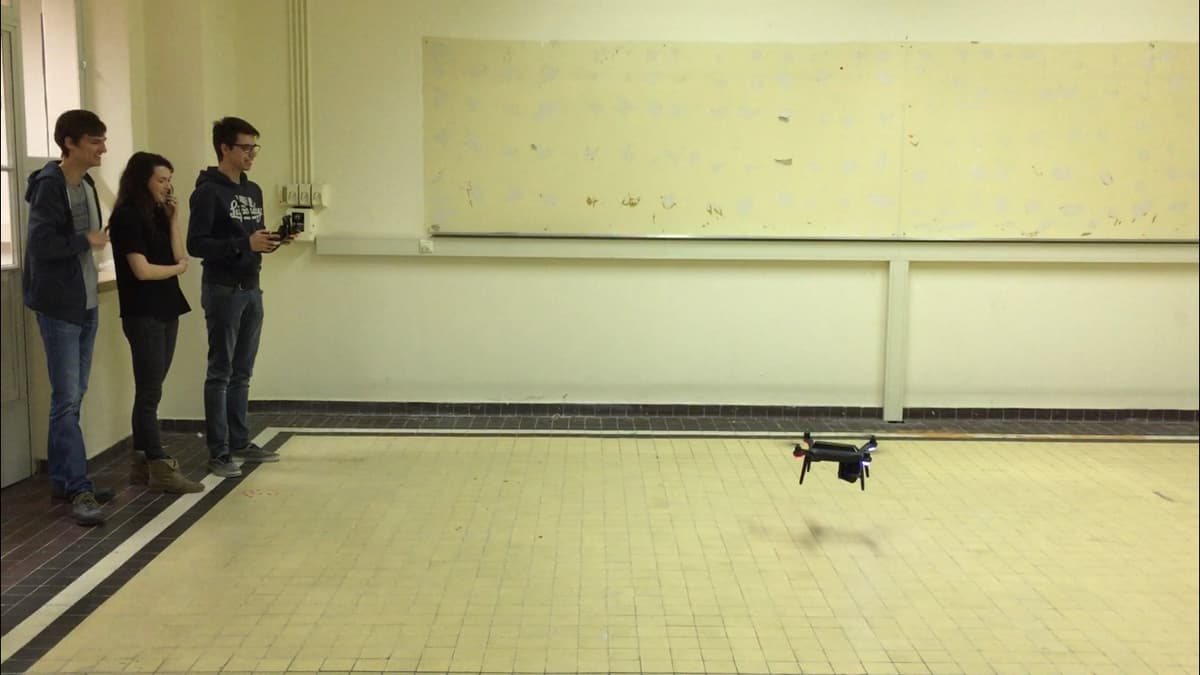
Bachelor Thesis - Drone Navigation
Investigated programmatic drone control and environmental navigation with a team of 3 students. Created a simulation environment from scratch in Processing for drone navigation in unknown environments.
project
Year: 2017
Timeline Details
About This Item
Investigated programmatic drone control and environmental navigation with a team of 3 students. Created a simulation environment from scratch in Processing for drone navigation in unknown environments.
Year
2017
Skills & Technologies
project